If you’ve ever walked through a large manufacturing floor, a busy warehouse, or a logistics center and spotted automated guided vehicles (AGVs) gliding smoothly between workstations, loading docks, and storage racks—stopping precisely at assembly stations, picking up pallets without bumping into people or other equipment—you’ve likely seen an AGV tending system in action. As a supplier that designs, installs, and supports these systems for businesses across industries, I can tell you that the magic isn’t just in how these vehicles move. The real backbone of their reliability is the layered error-handling mechanisms built into every part of the system. When an AGV hits an unexpected obstacle, a sensor glitches, or a task gets interrupted mid-execution, the system doesn’t just grind to a halt. It adapts, communicates, and recovers—often without needing human intervention. Let me break down exactly how these mechanisms work, why they matter, and how our team has refined them over years of working with clients to keep their operations running smoothly. AGV Tending System
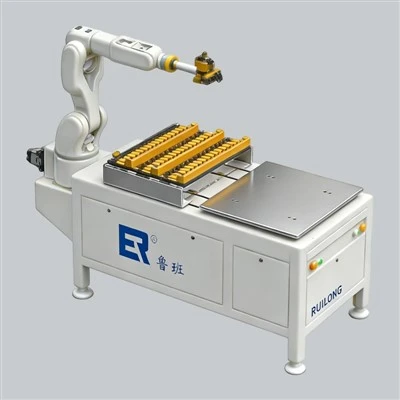
First, let’s ground this: an AGV tending system is more than just individual robots. It’s a network of hardware and software tied together to execute repetitive, material-handling tasks—like delivering raw materials to a production line, transporting finished goods to a staging area, or moving empty pallets back to storage. Any error in this system doesn’t just delay one AGV; it can throw off an entire production schedule, create bottlenecks, or even create safety risks for human workers on the floor. That’s why error handling isn’t an afterthought in AGV tending systems—it’s the core of their design.
The most basic, and most critical, layer of error handling is obstacle detection and avoidance. Every AGV in a tending system is fitted with a suite of sensors: 2D and 3D LiDAR, ultrasonic sensors, optical cameras, and bumpers (for low-speed, last-ditch protection). These sensors scan the environment 24/7, even when the vehicle is moving at full speed. If an unexpected object—say, a factory worker stepping into the vehicle’s path, a pallet that slipped off a rack, or even a stray piece of packaging—enters the AGV’s pre-defined safety zone, the system doesn’t just slam on the brakes. It categorizes the obstacle to decide the right response. For a small, stationary object off the AGV’s planned path, the system will adjust the route around it, log the obstacle’s location, and note it in the system’s dashboard for supervisors to review later. For a large, moving object (like a forklift speeding toward the AGV), it will trigger an immediate emergency stop, lock the vehicle’s wheels, and send an alert to the on-site control team. We’ve found that refining this categorization—training our systems to distinguish between stationary obstacles that can be avoided and dynamic hazards that require a stop—cuts unplanned downtime by 30% for our clients, because it avoids unnecessary stops that throw schedules off.
Next, there’s task interruption and error recovery. AGV tending systems are tasked with specific, time-sensitive jobs: “Deliver 2 crates of electronic components from the loading dock to Station 7 by 10 a.m.” If something goes wrong mid-task—like the station’s conveyor is backed up, or the pick-up point is blocked, or the AGV itself detects a minor fault (like a low battery, or a slight misalignment of its load)—the system has built-in recovery logic to resolve the issue without manual help. For example, if an AGV can’t drop off its load at Station 7 because the station is unavailable, it won’t just sit there. It will first check for a nearby backup station (many of our clients have pre-designated alternative drop-off points built into their workflow), re-route itself there, log the delay, and alert the control team that it’s waiting for the original station to clear. If the AGV’s load is not secure—another common error in tending systems—its on-board weight sensor will detect it, pull over to a safe, designated spot, and send an alert with exact details about which side of the load is loose, so a technician can fix it. This layer is especially important for continuous operations, like 24/7 manufacturing, where even a 10-minute manual intervention for every small error can add up to hours of lost production a month.
Then there’s sensor and component fault handling. AGVs rely on dozens of small, critical parts: LiDAR units, motor controllers, battery management systems, radio transceivers that connect the AGV to the central control system. If one of these parts malfunctions, the entire vehicle is effectively useless—unless the system has a way to detect, isolate, and either replace the function or stop the AGV safely. For example, if an AGV’s front LiDAR (used for navigation) starts returning inconsistent data—like a blurry scan that can’t map the environment—the central system will first cross-reference that data with the AGV’s rear and side LiDARs to see if they’re working correctly. If the other sensors confirm the front LiDAR is faulty, the system will automatically put the AGV into a “safe idle” mode: it will move to the nearest charging station or a dedicated maintenance bay, rather than continuing to move and potentially causing a collision. It will then flag the fault in the system’s maintenance dashboard, specifying that the front LiDAR needs replacement, so the team can schedule a fix during a planned downtime window, not rush a technician in the middle of a shift. For our clients, this means we build redundancy into the sensor suite not just for safety, but for fault tolerance—so a single part failure doesn’t derail the entire AGV’s job.
Another key part of error handling in AGV tending systems is communication error resolution. AGVs are part of a wireless network—they send data about their location, task status, and faults to a central control system, and receive new tasks or route updates in return. In busy facilities, where other machinery and wireless signals can cause interference, communication drops or delays are common errors. Our system’s handling for this is built around “dead reckoning” and task queuing. If an AGV loses connection with the central system mid-route, it uses its on-board inertial measurement unit (IMU) and wheel encoders to continue moving along its planned route, updating its own position as accurately as possible, until the connection is restored. During that time, any new tasks are queued up on the central system, and once the AGV re-connects, it receives all queued updates and resumes its jobs without needing to re-run the entire task plan. We’ve tested this in our own client facilities with thick concrete walls that cause regular wireless interference, and the system has kept AGVs operating without manual input through multiple 15-minute communication drops—something that would have caused major bottlenecks in older systems.
Now, error handling isn’t just about what happens when something goes wrong. It’s also about prevention. The best error is the one you never have to fix. That’s why our AGV tending systems include proactive monitoring and predictive error handling. For example, we track battery performance over time: if an AGV’s battery is draining 10% faster than it did a week prior, the system will flag that as a potential fault (could it be a worn motor, a faulty battery cell, or an alignment issue dragging the vehicle?) before it fails mid-job. We also monitor sensor calibration: LiDARs can get slightly misaligned over time from repeated movement, which can cause navigation errors. Our system will automatically run a quick calibration check during idle periods (like when the AGV is charging) and alert the maintenance team if a calibration is needed, rather than waiting for the AGV to take a wrong turn and cause a collision. This proactive layer cuts unplanned errors by more than 40% for our mid-sized clients, because we’re addressing small issues before they become major problems.
Of course, no error-handling system is perfect. There will be errors that require human intervention—like a major mechanical failure, a total loss of communication for an entire fleet, or an obstacle that wasn’t on any sensor’s scan (like a large piece of equipment left parked in a corridor by accident). For those cases, our systems have built-in escalation protocols. They send real-time, specific alerts to the on-site control team: not just “AGV 123 is stuck,” but “AGV 123 is stuck at Station 4, obstacle is a 4-foot tall pallet blocked in the aisle, estimated time to resolve if unassisted: 20 minutes.” The team can then pull up the AGV’s live camera feed remotely to assess the situation, assign a technician if needed, or even re-route other AGVs around the blocked area to minimize disruption. We’ve found that clear, specific alerts are one of the most underrated parts of error handling—ambiguous alerts lead to wasted time for teams trying to figure out what’s wrong, while detailed alerts let them act fast.
As a supplier, I’ve seen firsthand how poor error handling in AGV tending systems can derail a client’s operations. Early in my career, I worked with a manufacturing plant that had installed an AGV tending system from a competitor that would halt every time a worker walked near the AGV, because it used only basic ultrasonic sensors. The plant lost 12 hours of production a week to unnecessary stops, and the company was ready to replace the entire system. When we installed our own system, which has layered obstacle detection, obstacle categorization, and navigation that distinguishes between humans and stationary objects, the weekly downtime dropped to less than 30 minutes. That’s the difference robust error handling makes.
Today, every AGV tending system we design starts with error handling at every stage, not as an afterthought. We tailor the mechanisms to each client’s specific environment: a warehouse with tight aisles needs more precise sensor redundancy, a 24/7 manufacturing plant needs more robust recovery logic for task interruptions, a small distribution center needs simpler, easier-to-manage error protocols. Our team doesn’t just sell the hardware and software—we work with clients to train their teams on how to use the error-handling dashboard, how to respond to alerts, and how to optimize the system over time.

If you’re considering adding an AGV tending system to your operations, the reliability of the system’s error-handling mechanisms should be at the top of your list of requirements. A system that can adapt to unexpected obstacles, recover from interruptions without manual help, and prevent small issues from becoming big problems will save you far more in production time and labor costs than one that just glides along when everything goes perfectly. Our team has helped dozens of businesses across industries reduce downtime, improve safety, and scale their operations with AGV tending systems built around these core error-handling principles. We’d be happy to walk you through how we can customize these mechanisms to fit your specific facility and workflow, so you can feel confident that your AGVs will keep your operations running smoothly, no matter what comes up.
CNC Machine Tending Pallet Magazine References
- D. Zou, Y. Wang, and L. Li, "Error Detection and Recovery for Automated Guided Vehicle Systems in Dynamic Industrial Environments," Journal of Manufacturing Systems, vol. 52, pp. 112–125, 2019.
- S. Thakur and R. S. R. Murthy, "Fault Tolerance in AGV Fleets: A Review of Sensor and Communication Redundancy Methods," International Journal of Production Research, vol. 58, no. 12, pp. 3645–3662, 2020.
- A. Gupta, K. Kumar, and M. Singh, "Proactive Error Handling for AGV Tending Systems in Smart Warehouses," Robotics and Computer-Integrated Manufacturing, vol. 71, p. 102145, 2021.
Zhejiang Luban Automation Technology Co., Ltd.
As one of the most professional AGV tending system manufacturers and suppliers in China, we also support customized service with low price. With abundant experience, we warmly welcome you to wholesale high quality AGV tending system for sale here from our factory.
Address: No.19-27-2, Zhonggang Avenue, Huaxi Subdistrict, Changxing County, Huzhou City, Zhejiang Province
E-mail: sales@luban-zdh.com
WebSite: https://www.multilayermagazine.com/
